Pallet recognition
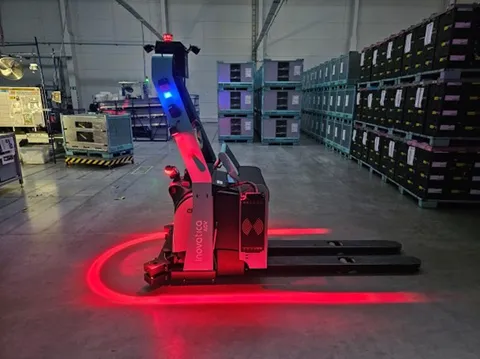
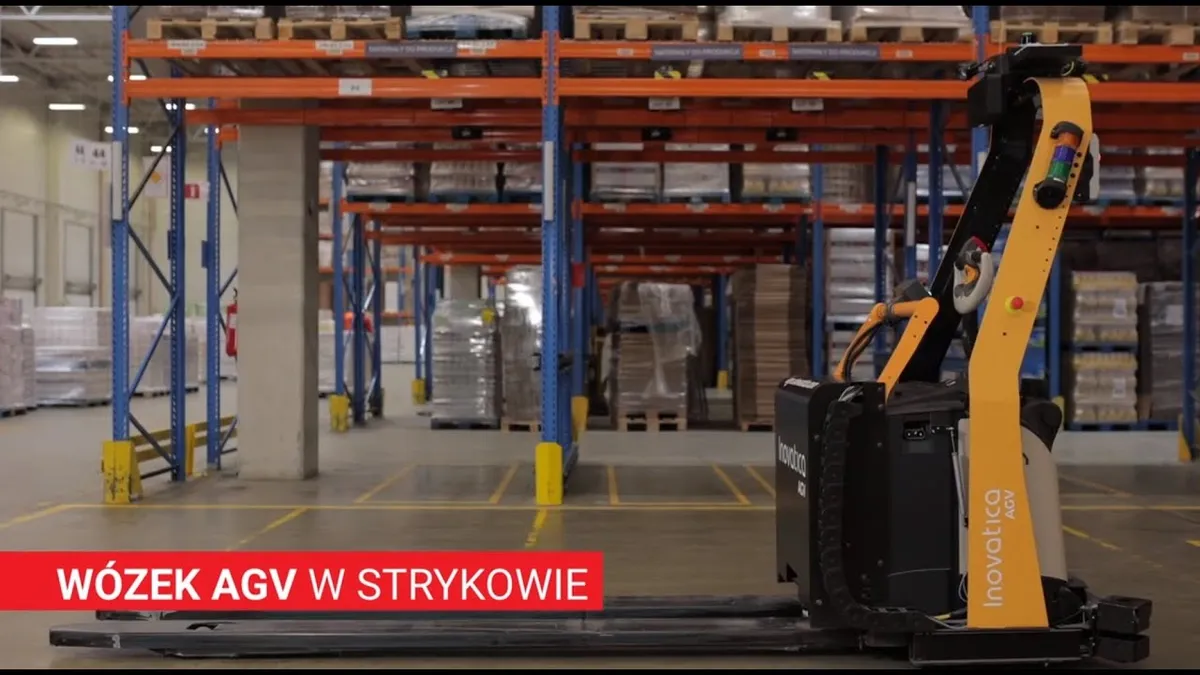
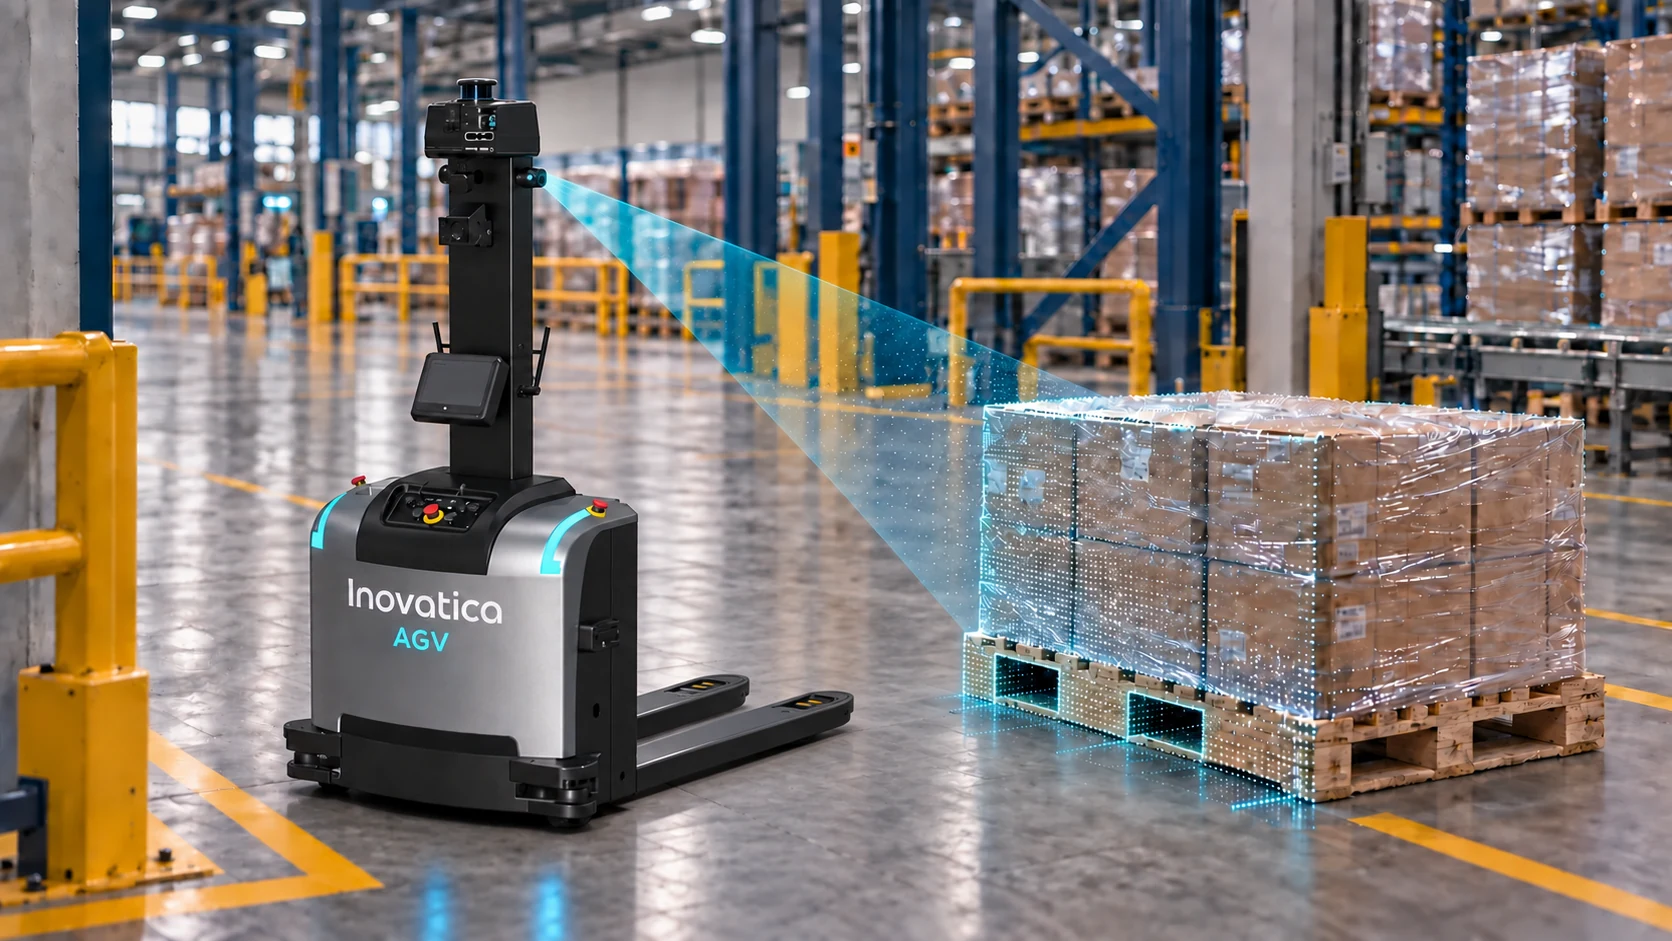
The 3D vision module helps an autonomous forklift pick up a pallet accurately even when it is not placed exactly at its designated position. It compensates for position and rotation deviations caused by manual placement or conveyor handoff.
3D camera → pallet position → fork correction
1
Approach
The AGV approaches the pallet and stops at the recognition point.
2
3D scan
The camera produces a point cloud. The AI algorithm calculates the actual X, Y and Z offsets and the pallet’s yaw angle.
3
Pickup correction
The AGV adjusts its position and fork path to enter the pallet openings despite placement deviations.
Recognition parameters
Performance depends on the pallet model and geometry and should be confirmed for each deployment.
- pallet angle correction
- up to 30°
- lateral offset correction
- up to 30 cm
- recognition and positioning accuracy
- 15 mm
- optimal recognition distance; 30 cm minimum
- 1.0–2.5 m
- typical measurement cycle
- 0.5–2 s