3D obstacle avoidance
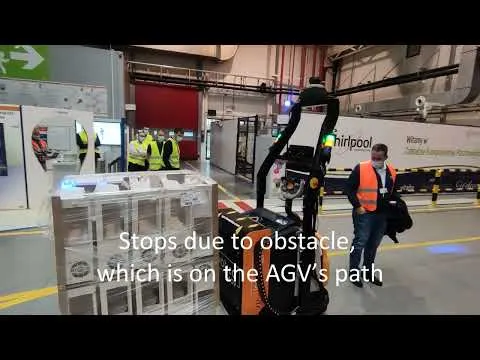
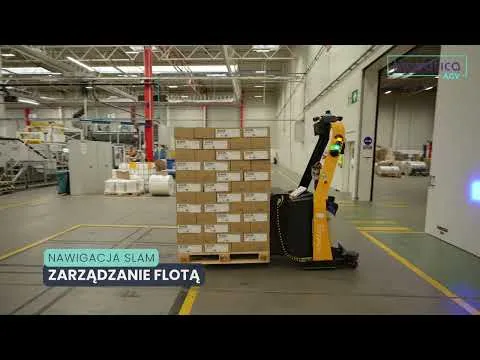
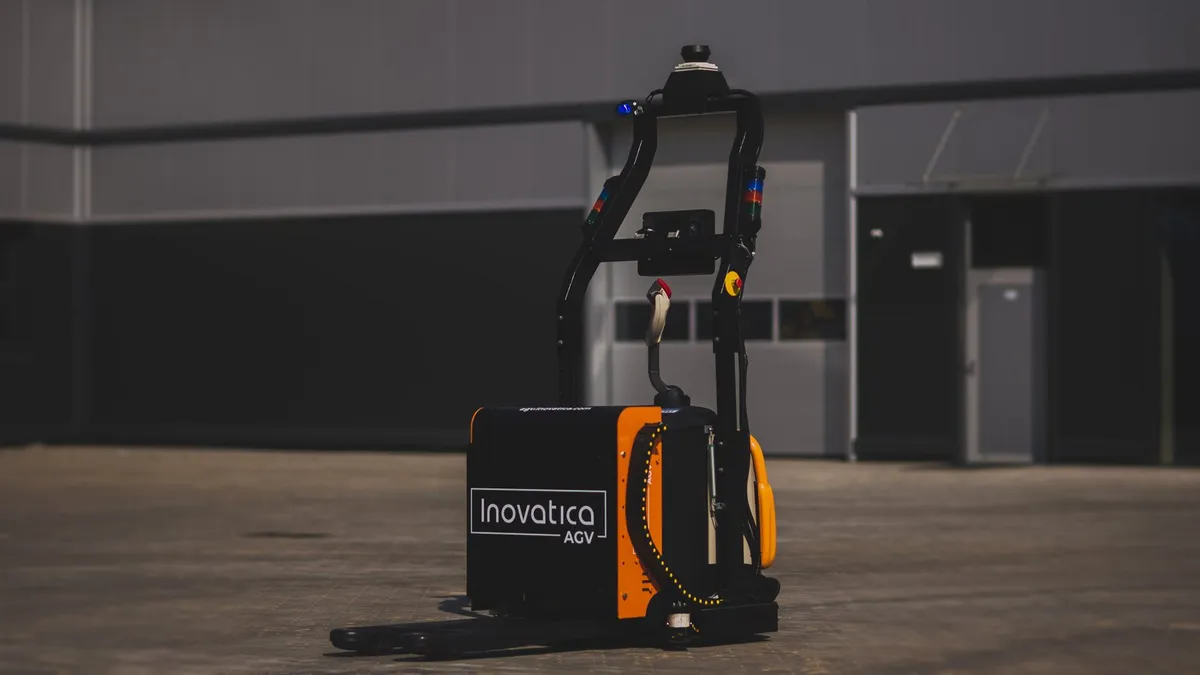
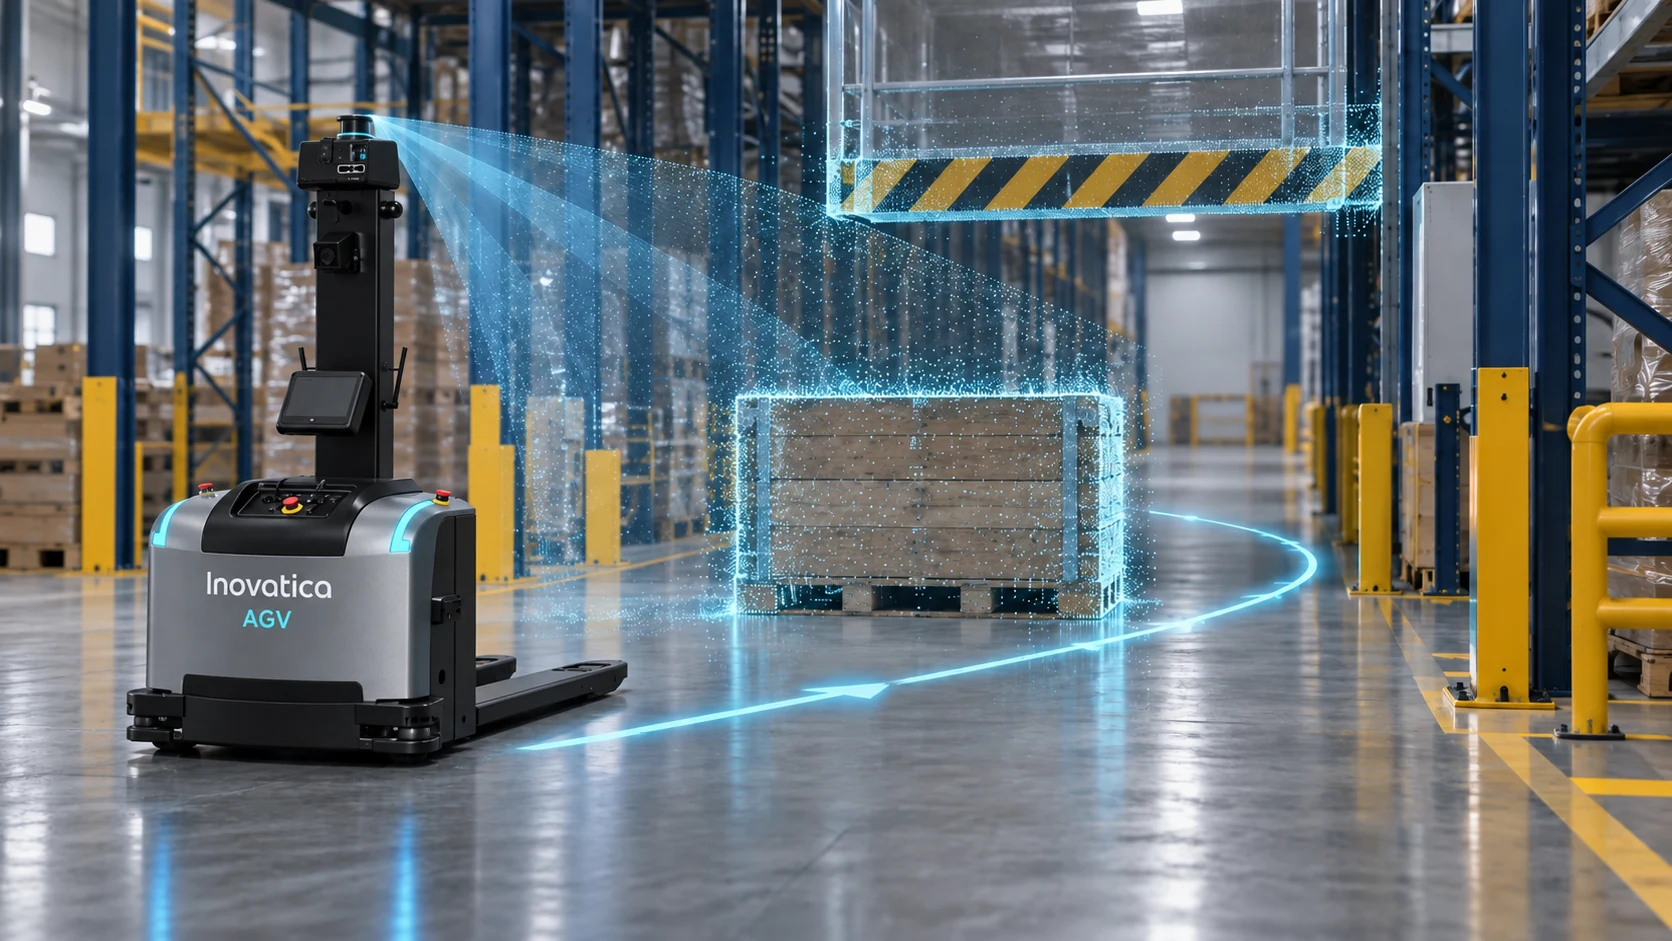
A 3D depth camera connected to the AGV controller analyses the space ahead in real time. It can detect obstacles above the plane covered by a 2D scanner and, when a route is blocked, support a detour before the vehicle rejoins its planned path.
3D scan → blocked-path check → detour
3D detection
A depth camera creates a point cloud ahead of the vehicle and detects obstacles above the plane covered by a 2D scanner.
Blocked-path check
The system stops the AGV and checks whether the obstruction clears. BlockToAvoidTime sets the wait before a detour is considered.
Detour and return
When the operating area permits it, free navigation plans a path around the obstacle and then rejoins the intended route.
What can the 3D camera detect?
Volumetric sensing covers obstacles near the floor as well as higher objects that a planar scan may miss.
- partly lowered barrier
- load projecting from a rack
- raised forks of a manual forklift
- pallet left on the route
Example configuration parameters
- Forward detection range
- up to 3.5 m
- Example camera installation
- 1.5 m / 58.5°
Camera geometry, range and permitted detours must be confirmed for the specific vehicle and facility.